Ajinkya JainHi! I am a Senior Research Scientist at Google (Intrinsic), where I am part of the R&D team led by Prof. Stefan Schaal. My research lies at the intersection of robot learning, embodied foundation models, and physics-informed control, focusing on methods that enable robots to perform dexterous, contact-rich, and multi-robot manipulation reliably in the real world. Recently, my work has centered on on-policy distillation and reinforcement learning finetuning, policy synthesis with foundation models (VLMs/LLMs), and force-aware imitation and online learning for tight-tolerance assembly. Previously, I was a Robotics Engineer on the R&D team at Vicarious (acquired by Alphabet in 2022 and integrated into Intrinsic). I received my Ph.D. in Robotics from The University of Texas at Austin under the guidance of Prof. Scott Niekum and Prof. Ashish Deshpande, where my doctoral research focused on learning object articulation and hybrid interaction models from visual data and motion planning under uncertainty. Prior to UT Austin, I earned my Dual Degree (B.Tech.–M.Tech.) in Mechanical Engineering (Robotics and Automation) from IIT Kanpur. |
|
ResearchMy research develops scalable learning and control algorithms for generalist, contact-rich robotic manipulation—spanning reinforcement learning finetuning and policy distillation, foundation models (VLMs/LLMs) for policy synthesis, force-aware imitation and online learning, sim-to-real transfer, and motion planning under uncertainty. Alongside my publications and patented industrial manipulation technology (US Patent 12,330,304 B2), I co-organize community workshops at RSS 2026, IROS 2026, and IEEE Humanoids 2026 on sim-to-real transfer and learning-based whole-body robot control. |
|
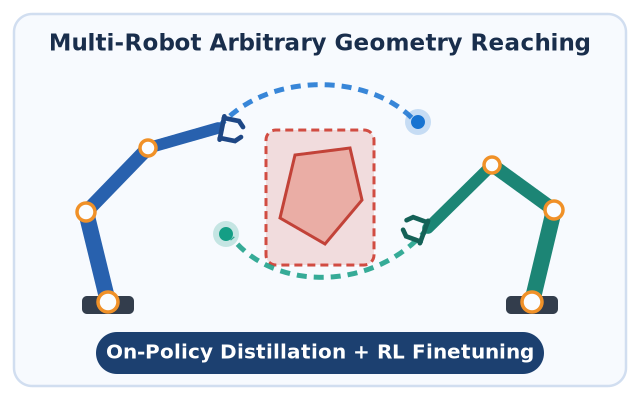
RoboBallet2: Multi-robot Reaching for Arbitrary Geometries via On-policy Distillation and Reinforcement FinetuningYuheng Zhi, Matthew Lai, Ajinkya Jain, Gautam Salhotra, Keegan Go, Gjermund Ustensvik, Torsten Kroeger, Stefan Schaal, and Michael C. Yip Under Review at IEEE Transactions on Robot Learning (T-RL), 2026 Scaling collision-free multi-robot reaching and motion generation across arbitrary 3D obstacle geometries via on-policy distillation from graph-neural-network experts and reinforcement learning finetuning. |
|
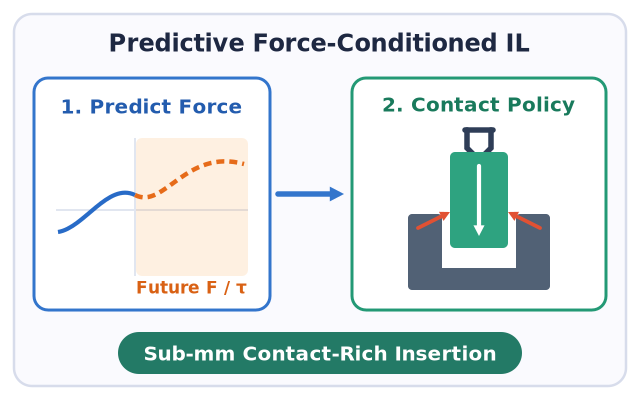
Predictive Force Conditioning for Contact-Rich Imitation LearningYigit Korkmaz, Keegan Go, Gautam Salhotra, Erdem Biyik, Ajinkya Jain, and Stefan Schaal Workshop on RoboData, Robotics: Science and Systems (RSS), 2026 A two-stage imitation learning architecture that explicitly forecasts future force-torque dynamics and conditions action generation on anticipated physical contact feedback for fine-grained, tight-tolerance manipulation. |
|
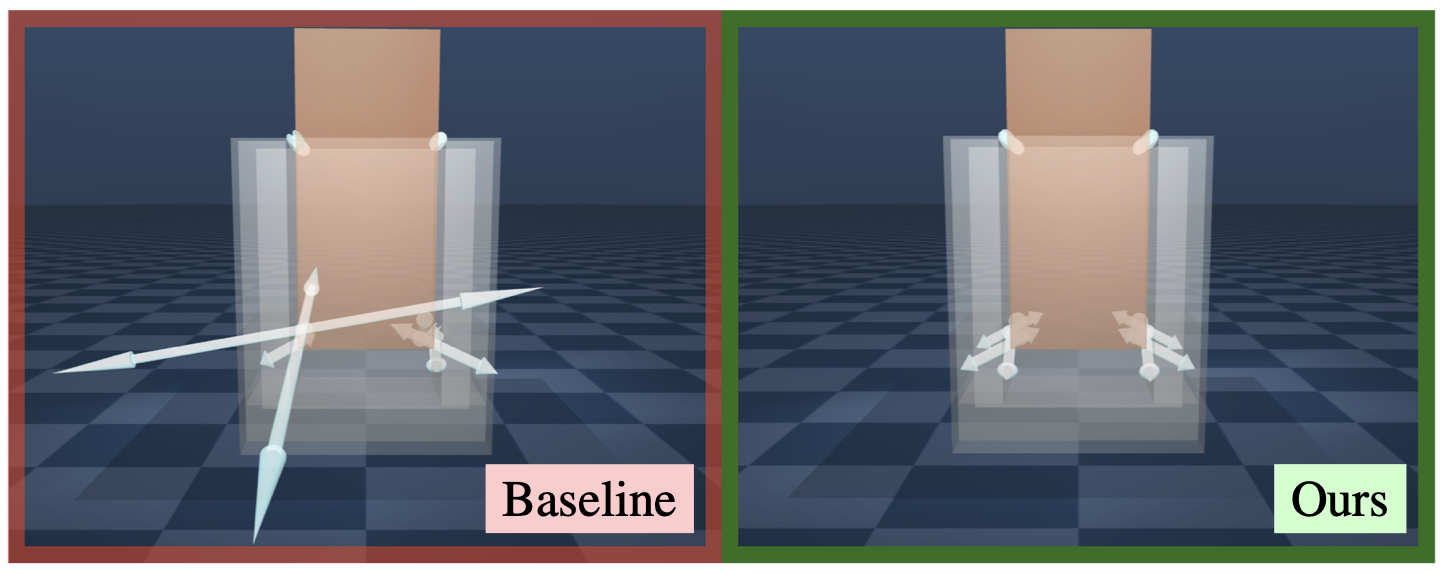
Efficient Online Learning of Contact Force Models for Connector InsertionKevin Tracy, Zachary Manchester, Ajinkya Jain, Keegan Go, Stefan Schaal, Tom Erez, and Yuval Tassa IEEE International Conference on Robotics and Automation (ICRA), 2025 paper / arxiv / webpage / code An efficient and scalable approach for modeling connector insertion environments by learning a quasi-static contact force model instead of a full simulator, employing a Linear Model Learning algorithm for real-time optimal mapping without matrix inversions. |
|
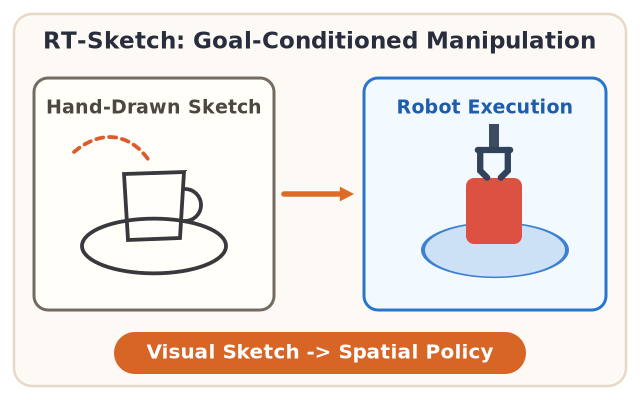
RT-Sketch: Goal-Conditioned Imitation Learning from Hand-Drawn SketchesPriya Sundaresan, Quan Vuong, Jiayuan Gu, Peng Xu, Ted Xiao, Sean Kirmani, Tianhe Yu, Michael Stark, Ajinkya Jain, Karol Hausman, Dorsa Sadigh, Jeannette Bohg, and Stefan Schaal Conference on Robot Learning (CoRL), 2024 arxiv / webpage A goal-conditioned manipulation policy that uses hand-drawn sketches for intuitive, spatially grounded, and distractor-robust goal specification in tabletop and articulated rearrangement tasks. |
|
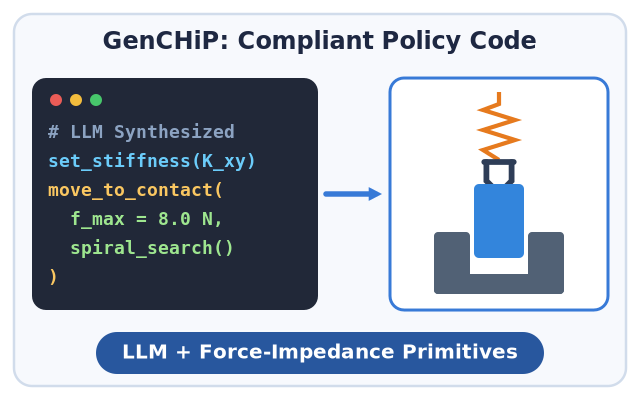
GenCHiP: Generating Robot Policy Code for High-Precision and Contact-Rich Manipulation TasksKaylee Burns, Ajinkya Jain, Keegan Go, Fei Xia, Michael Stark, Stefan Schaal, and Karol Hausman IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2024 arxiv / webpage Equips large language models with compliant impedance and force-constrained action primitives to synthesize zero-shot robot policy code for high-precision, tight-tolerance contact-rich manipulation tasks. |
|
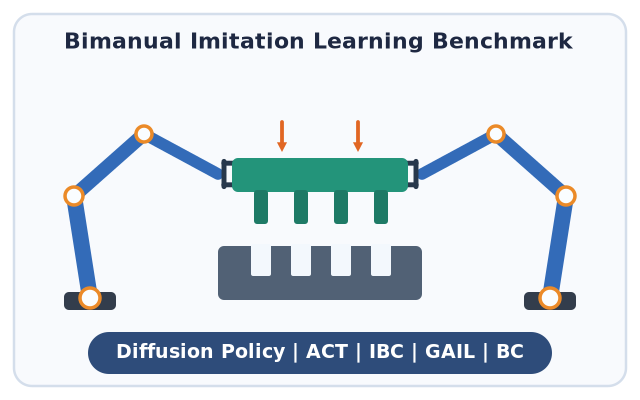
A Comparison of Imitation Learning Algorithms for Bimanual ManipulationMichael Drolet, Simon Stepputtis, Siva Kailas, Ajinkya Jain, Jan Peters, Stefan Schaal, and Heni Ben Amor IEEE Robotics and Automation Letters (RA-L), 2024 paper / arxiv / code A systematic empirical evaluation of modern imitation learning algorithms (Diffusion Policy, ACT, IBC, GAIL, DAgger, and Behavior Cloning) on over-constrained, high-precision bimanual insertion tasks. |

|
Open X-Embodiment: Robotic Learning Datasets and RT-X ModelsOpen X-Embodiment Collaboration (incl. Ajinkya Jain) IEEE International Conference on Robotics and Automation (ICRA), 2024 Best Conference Paper Award, ICRA 2024 paper / webpage / code Large-scale datasets in standardized data formats and models to enable learning “generalist” X-robot policy that can be adapted efficiently to new robots, tasks, and environments. |
|
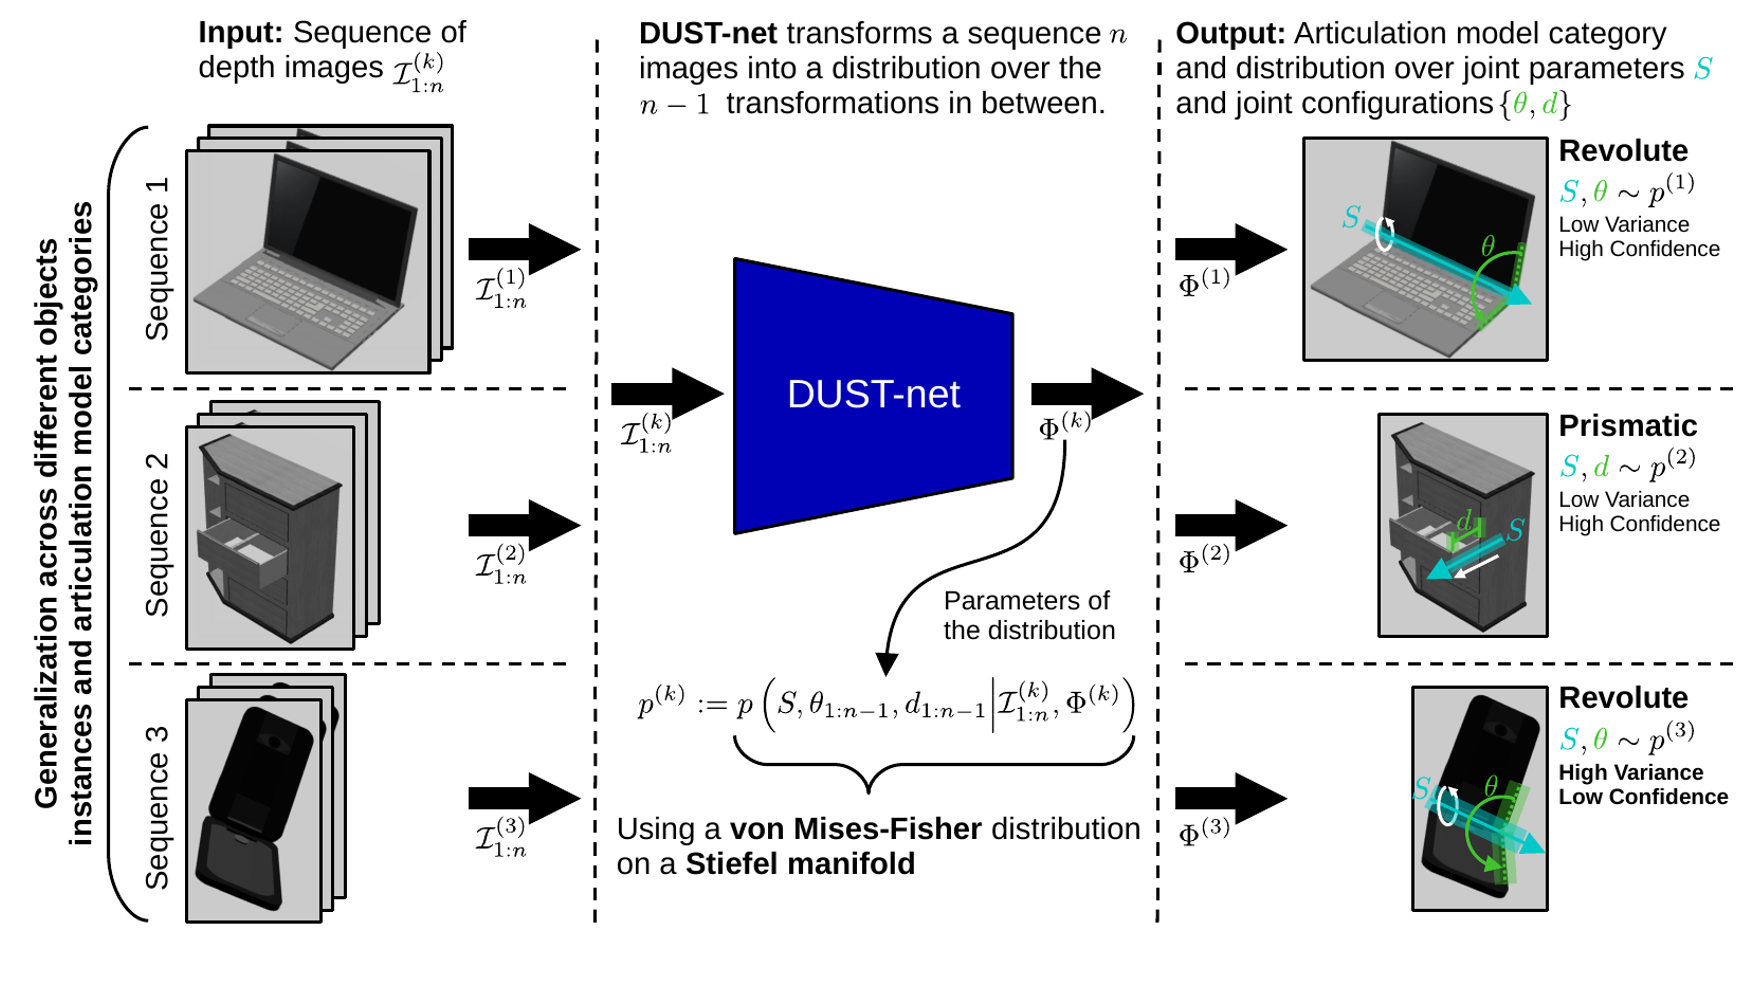
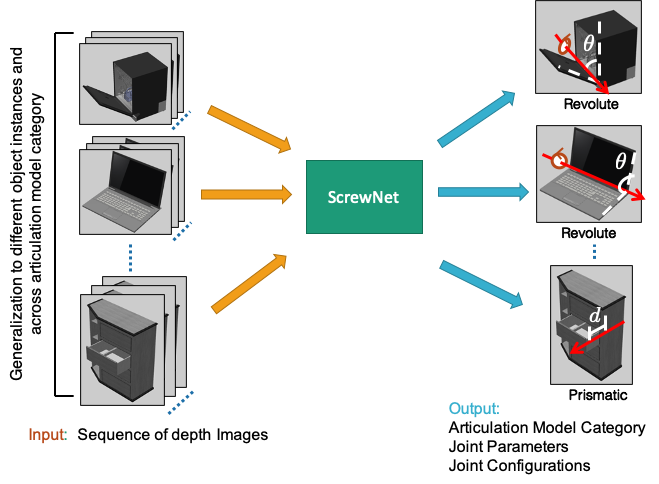
Distributional Depth-Based Estimation of Object Articulation ModelsAjinkya Jain, Stephen Giguere, Rudolf Lioutikov, Scott Niekum 5th Conference on Robot Learning (CoRL), 2021 paper / webpage / code / poster A novel method that efficiently learns distributions over articulation model parameters directly from depth images without the need to know articulation model categories a priori |
|
ScrewNet: Category-Independent Articulation Model Estimation From Depth Images Using Screw TheoryAjinkya Jain, Rudolf Lioutikov, Caleb Chuck, Scott Niekum IEEE International Conference on Robotics and Automation (ICRA), 2021 paper / video / webpage / code / poster A novel method for estimating articulation models for objects directly from raw depth images without knowing their articulation type a priori using screw theory |
|
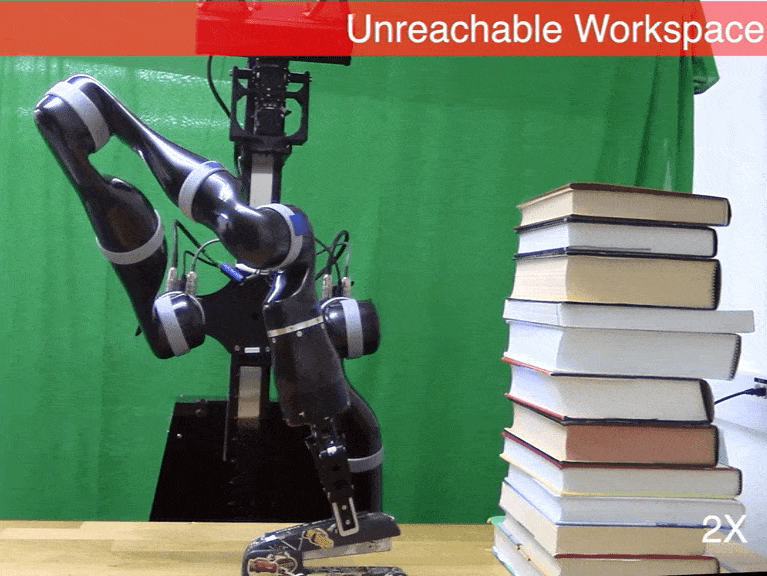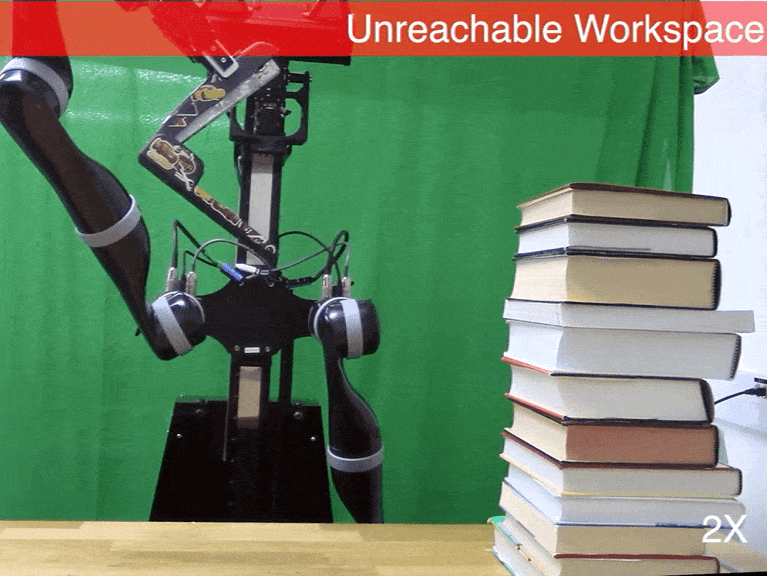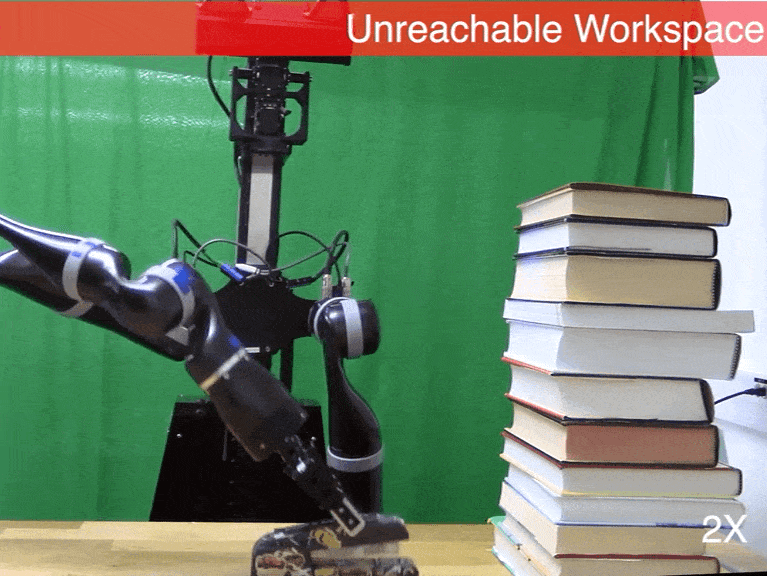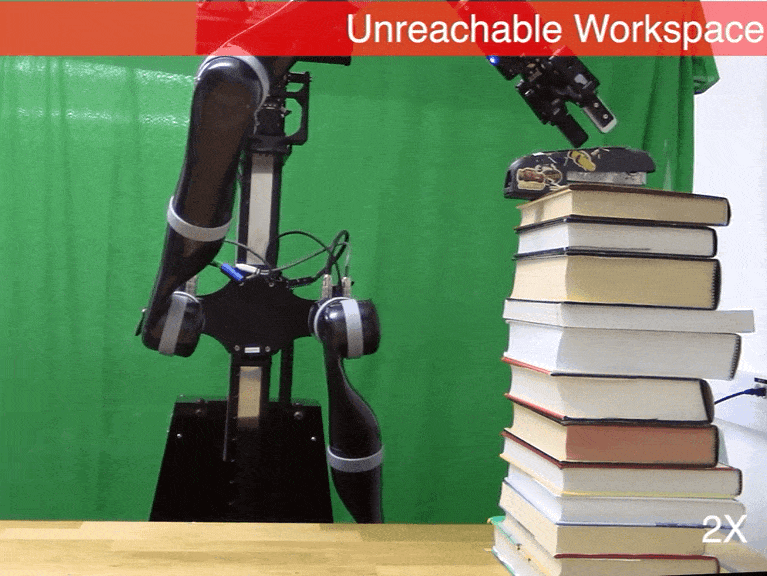
Learning Hybrid Object Kinematics for Efficient Hierarchical Planning Under UncertaintyAjinkya Jain, Scott Niekum IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2020 paper / video / slides A method for learning planning-compatible hybrid kinematics models for articulated objects from human demonstrations. |
|
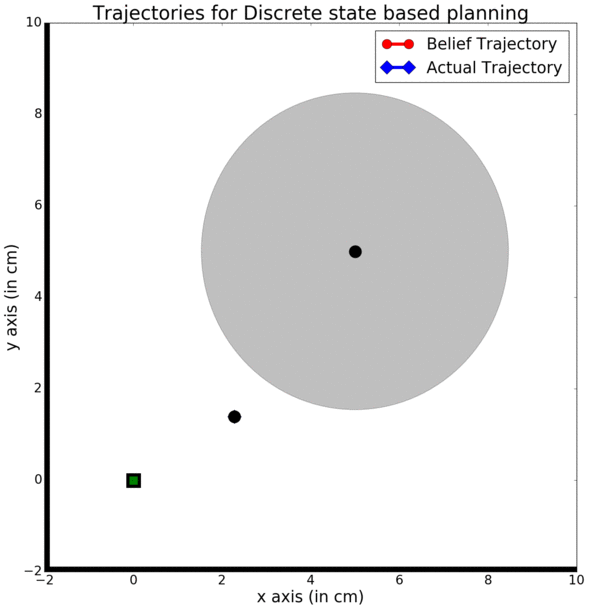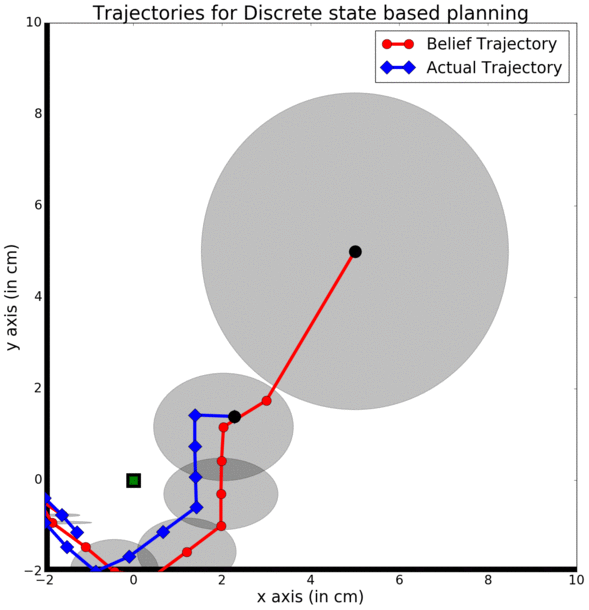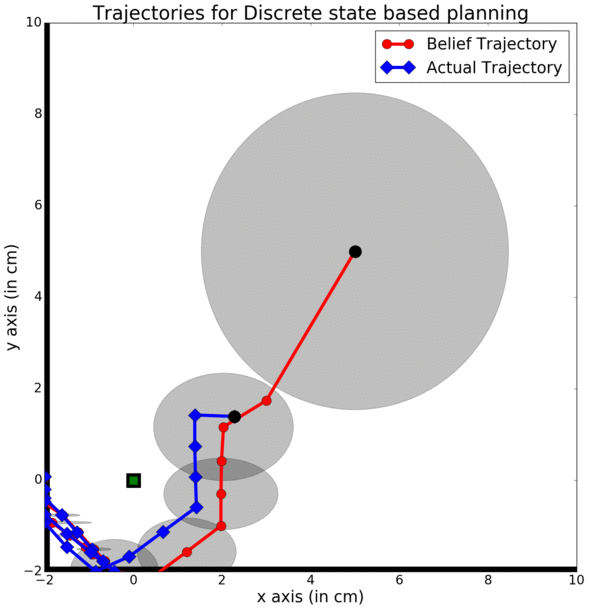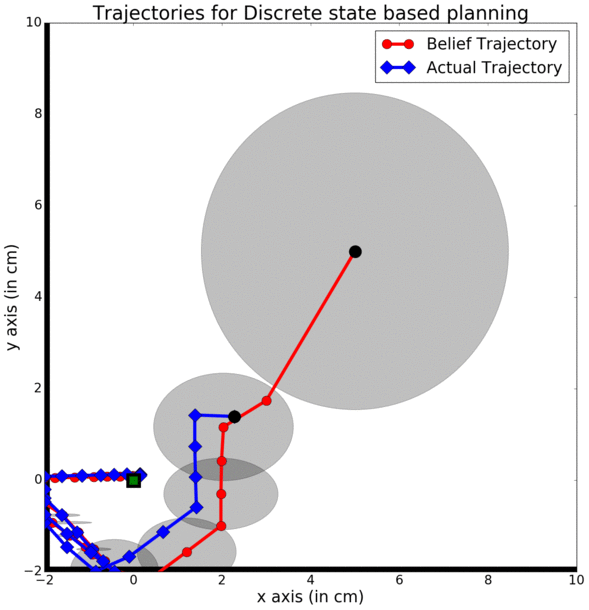
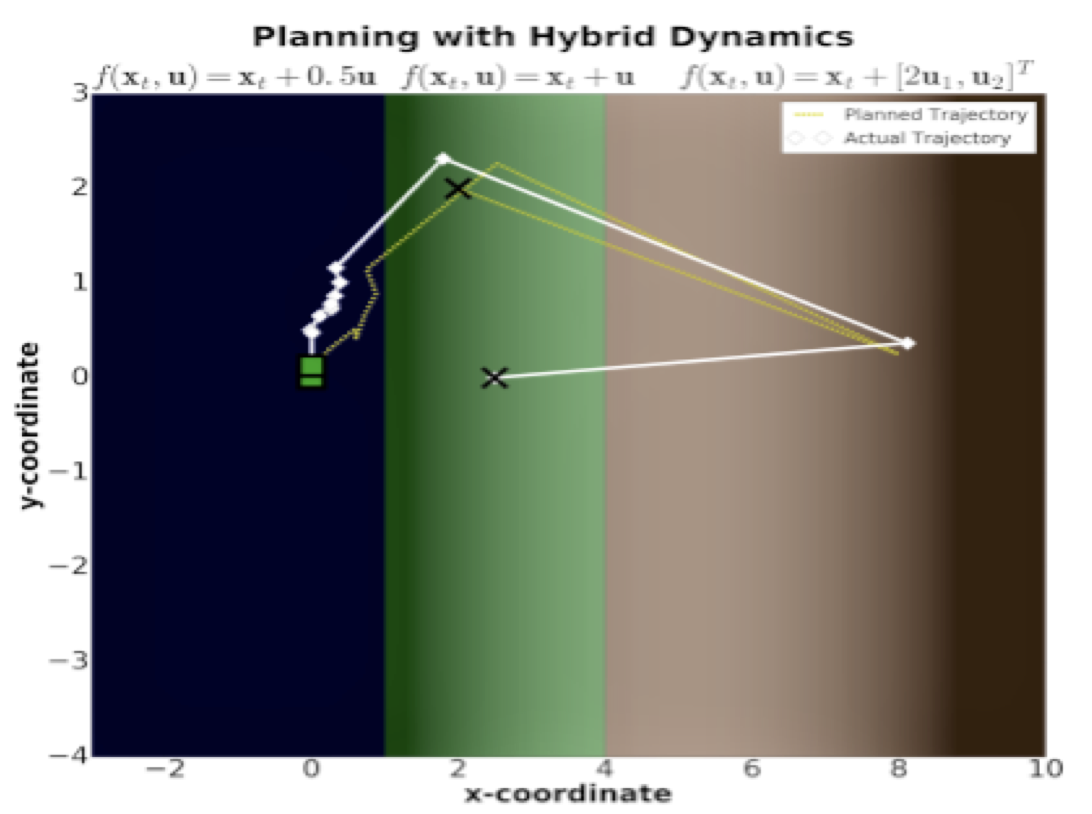
Efficient Hierarchical Robot Motion Planning Under Uncertainty and Hybrid DynamicsAjinkya Jain, Scott Niekum Conference on Robot Learning (CoRL), 2018 paper / video / code A POMDP-based Motion planner that generates efficient motion plans leveraging object-object interactions to perform manipulation tasks under uncertainty with high success rates |
|
Belief Space Planning under Approximate Hybrid DynamicsAjinkya Jain, Scott Niekum Workshop on POMDPs in Robotics, Robotics: Science and Systems (RSS), 2017 paper Extending Belief-space LQR to hybrid systems for robot motion planning under uncertainty |
|
A piezoelectric model based multi-objective optimization of robot gripper designRituparna Datta, Ajinkya Jain, Bishakh Bhattacharya Structural and Multidisciplinary Optimization, Springer, 2015 paper Multi-objective design optimization of a piezoelectric actuator driven gripper |
|
Unified Minimalistic Modelling of Piezoelectric Stack Actuators for Engineering ApplicationsAjinkya Jain, Rituparna Datta, Bishakh Bhattacharya Advances in Intelligent Systems and Computing, Springer, 2014 paper A simple, computationally-cheap, yet effective model for piezoelectric stack actuators as a replacement of black-box models used in engineering design optimization problems. |
|
Design and source code from Jon Barron's website. Jekyll version from Leonid Keselman's website |